Sentinel-1A / 22 May 2023 05:19 UTC
Castel Bolognese.
The Senio valley in Emilia-Romagna after the flood of 16–17 May 2023. Radar from 28 April 2023, 10 May 2023 and 22 May 2023, the classes of a model and of a simple baseline, and the Copernicus emergency mapping, each shown with its own date.
Read this first
A qualitative demonstration, not an accuracy claim.
The model never saw Italian data, and no independent labels exist for this flood. Its accuracy is measured only on the benchmark test set. The overlap with the emergency mapping below describes two maps; it is not accuracy. Not for emergency response or decisions about real places.
Compare the radar, the predictions and the reference.
Drag the divider, or focus it and use the arrow keys, to compare two layers. Choose each side’s layer in the panel. The view is kept in the address, so it can be shared.
Loading the map
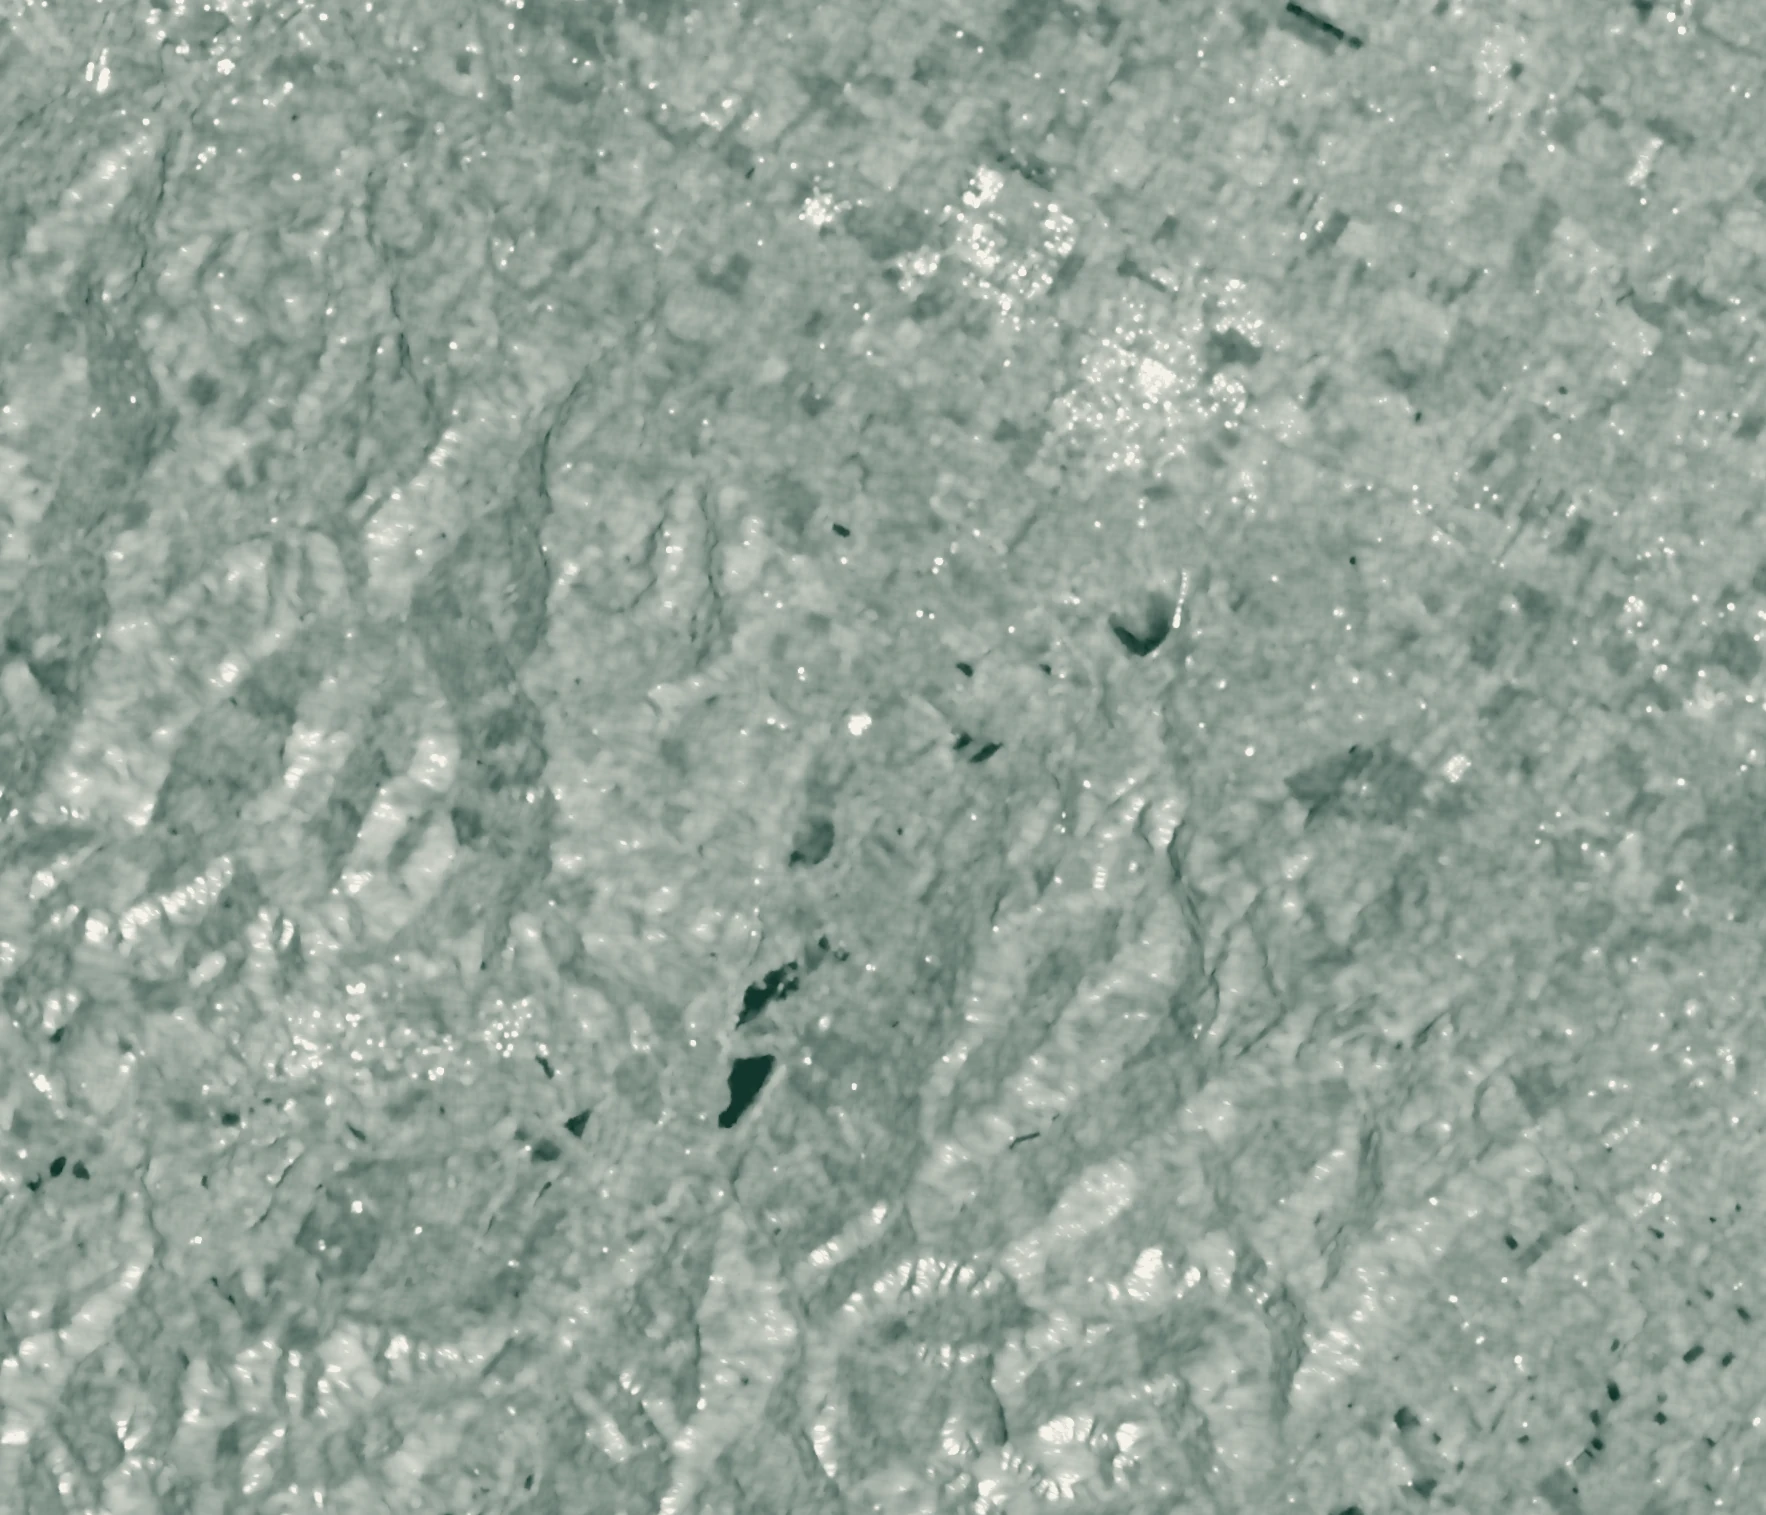
22 May 2023 radar
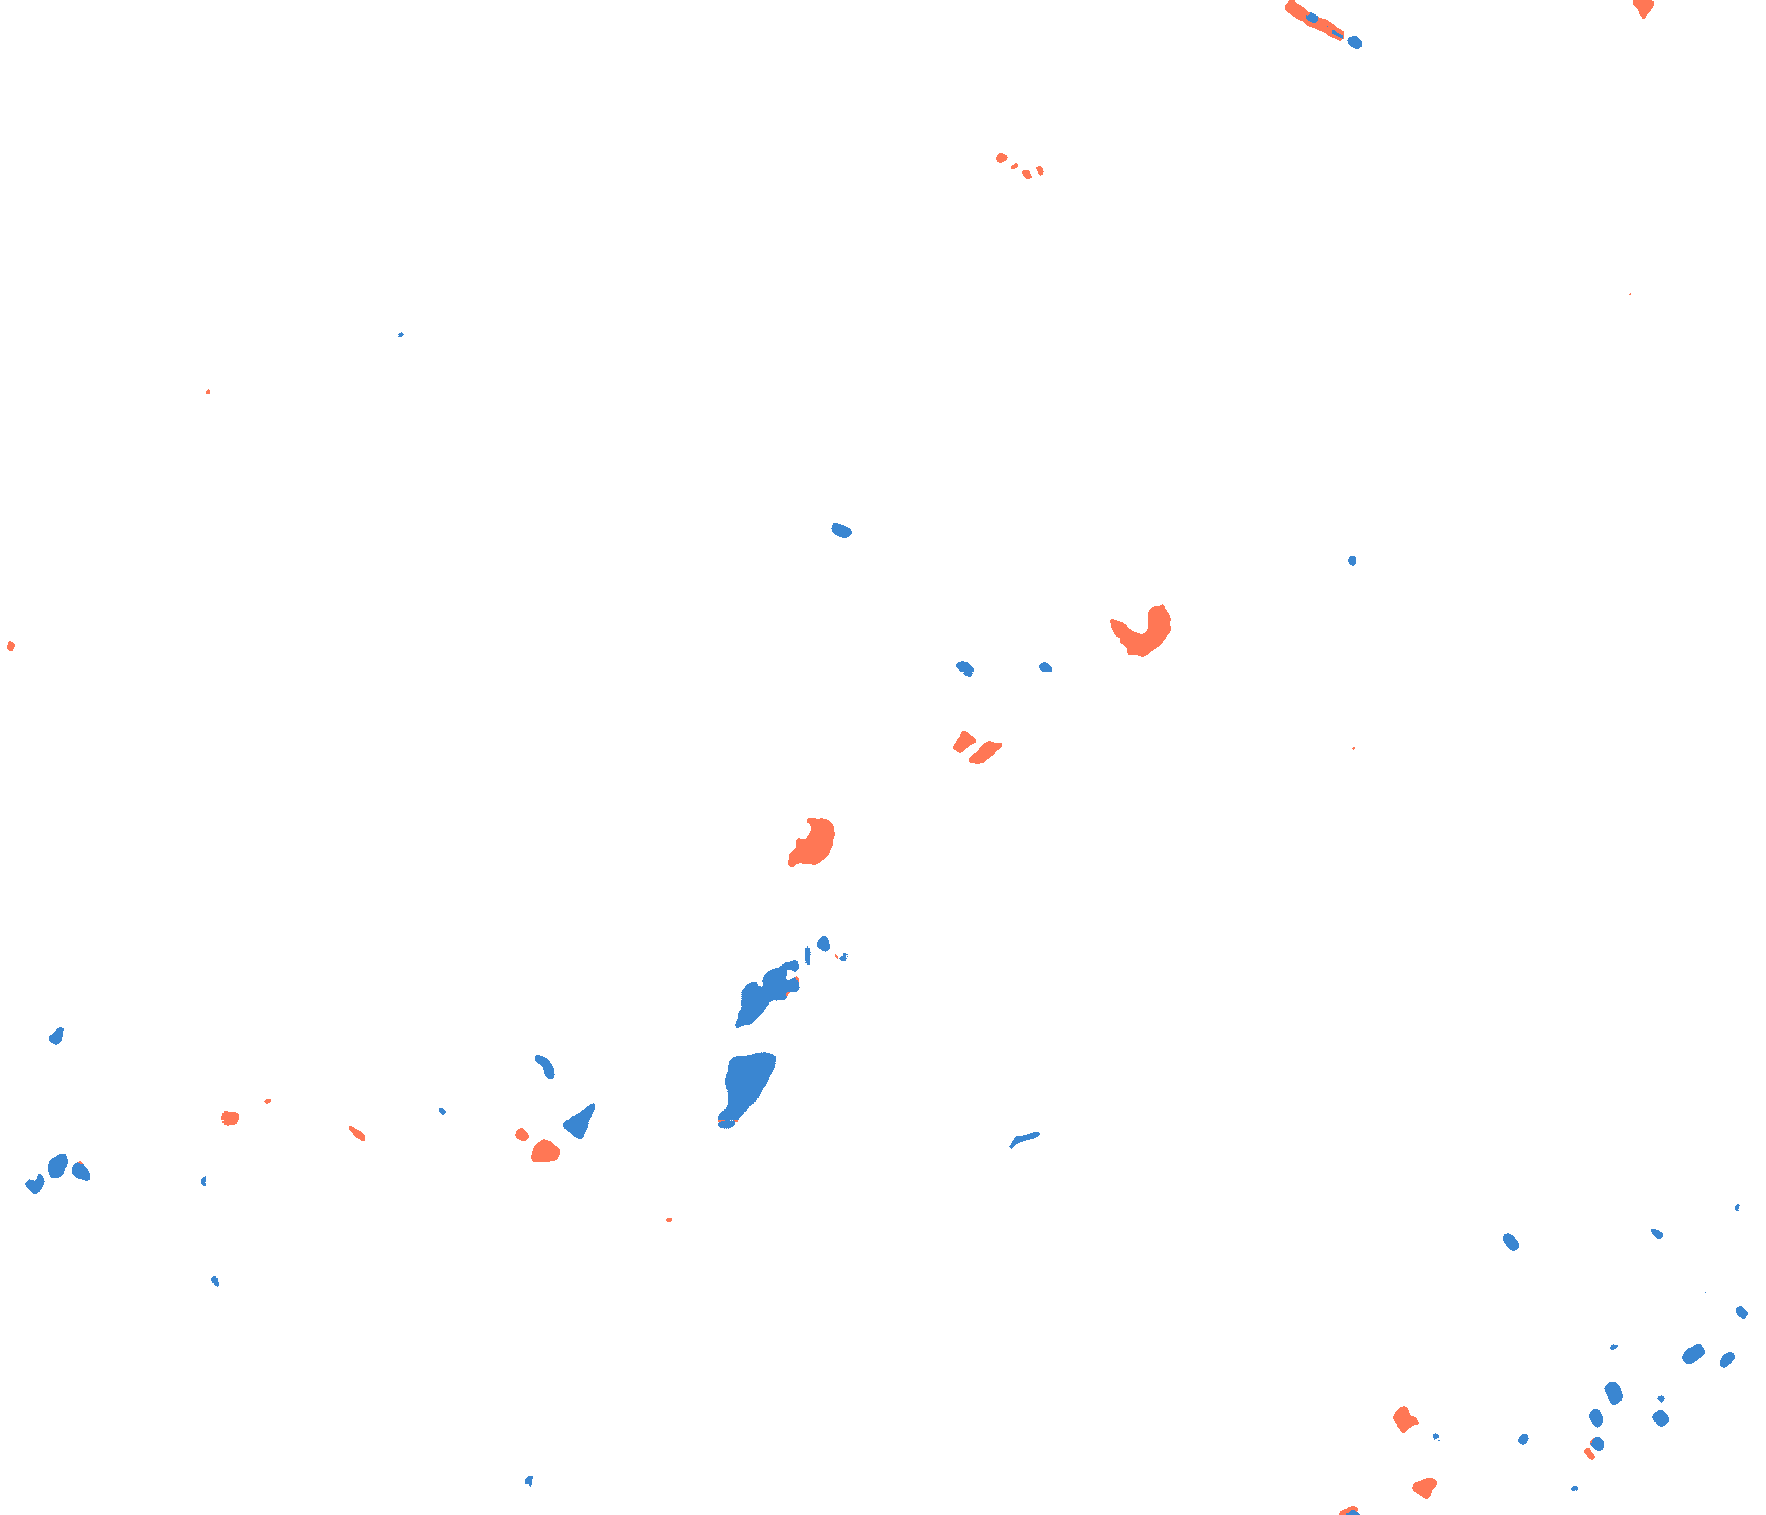
U-Net v1
Legend
Radar backscatter, VV
-22 dB0 dB
Dark: smooth surfaces such as open water. Bright: buildings and rough ground.
Predicted classes
- Permanent water
- Flood
- No data None in this event
- No water Transparent on the ground
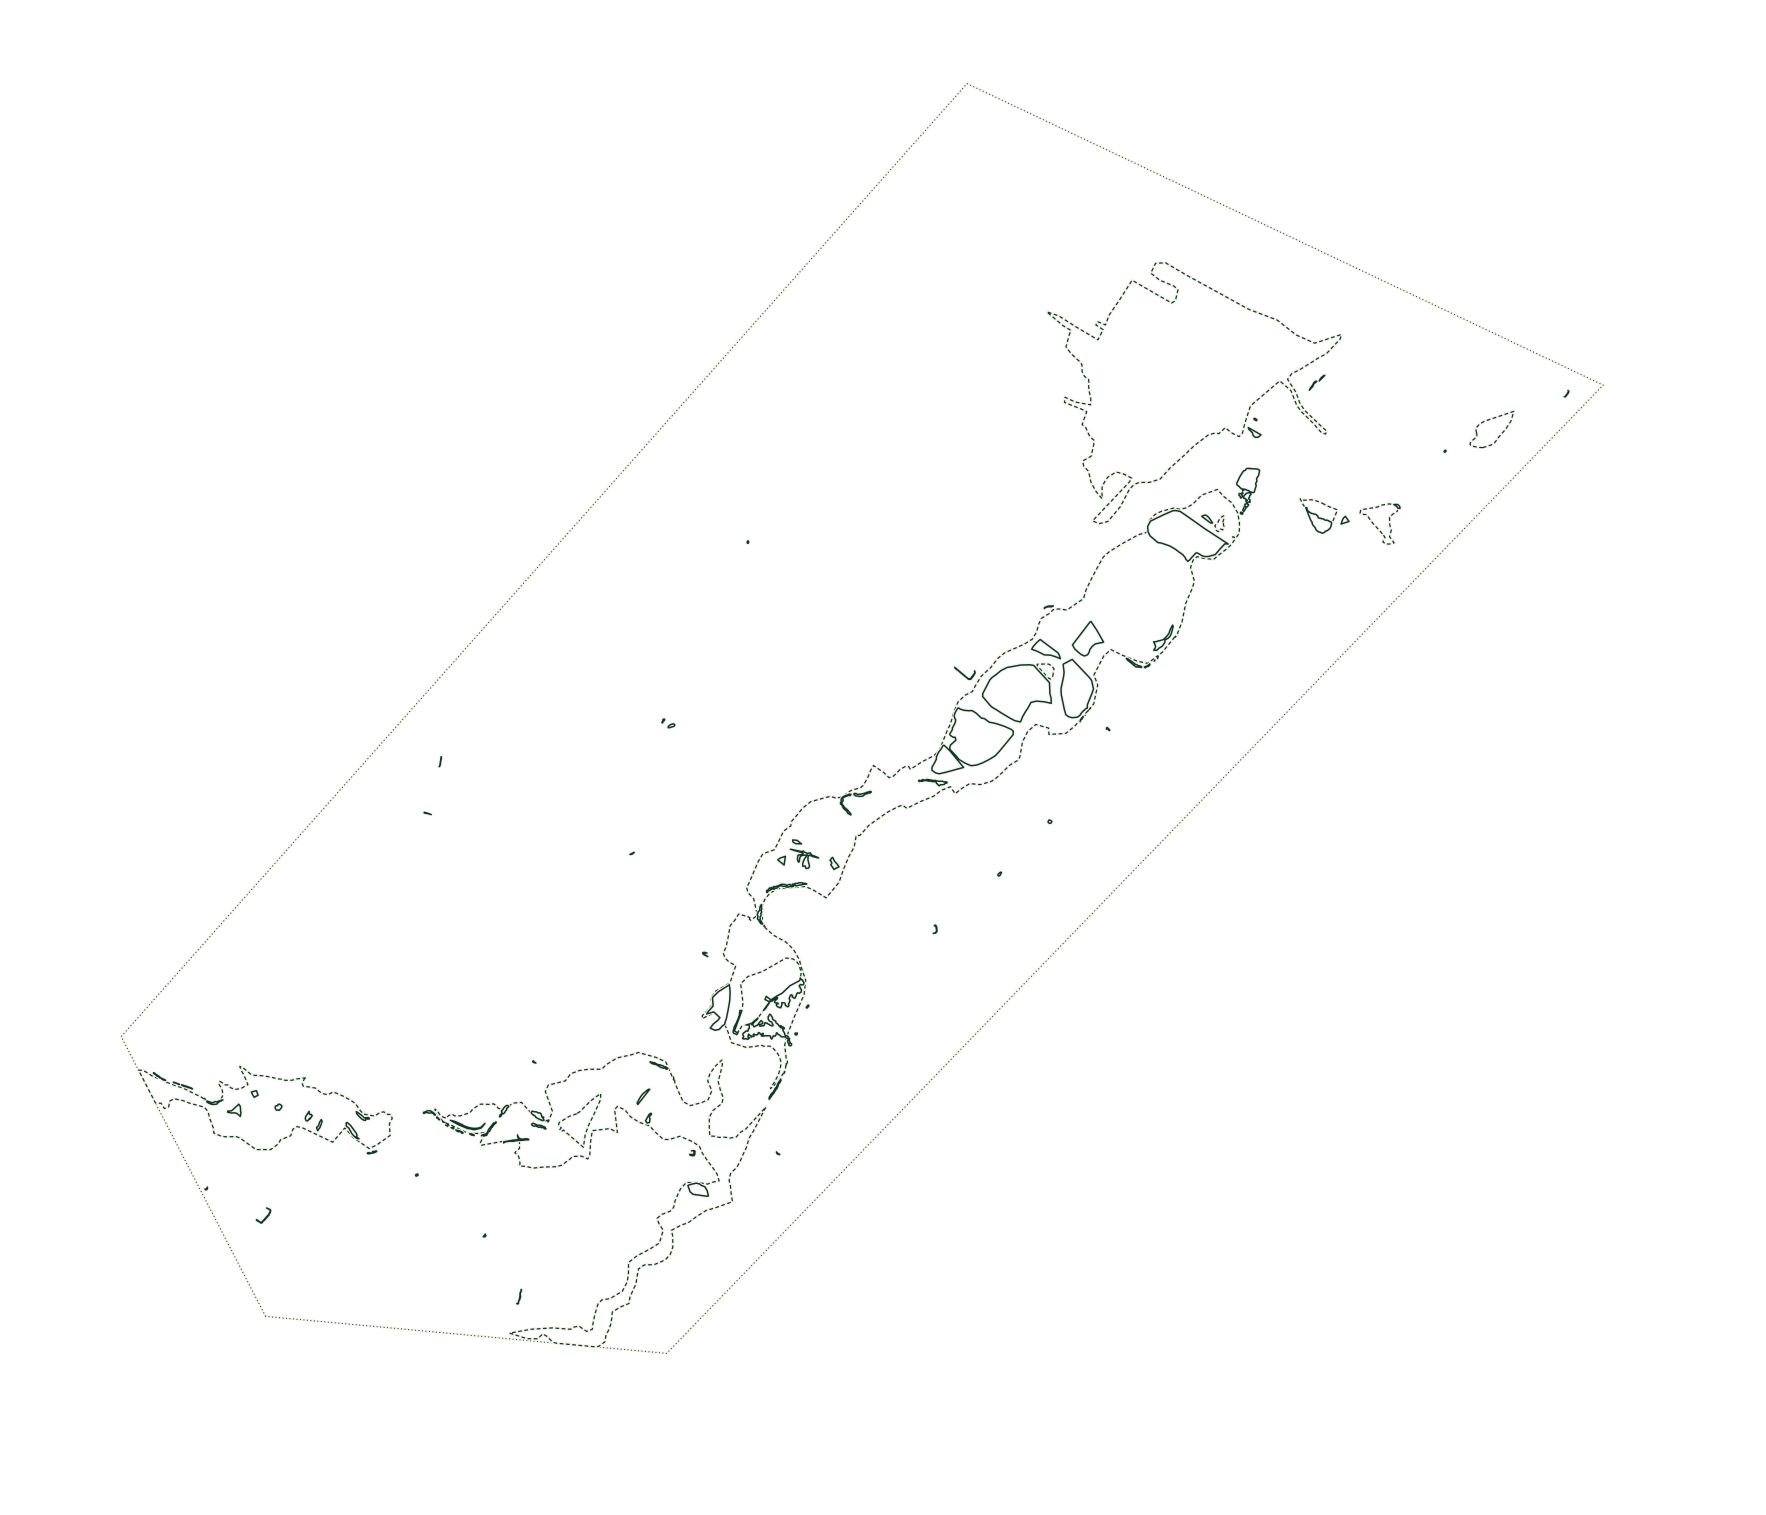
Reference, outlines only
- Flooded area
- Flood trace Deposits or damage, not standing water
- Area mapped by CEMS Outside it, nothing was mapped
Not shown
Layers cover only the model grid around Castel Bolognese; elsewhere the map shows the basemap alone. Flood probability is not published: the model’s scores are not calibrated, so only classes are shown.
Inputs
Sentinel-1A, VV and VH.
The model takes one post-event and two pre-event radar images, processed like the benchmark it was trained on. The map shows VV on a fixed stretch from −22 dB to 0 dB, the same for every date.
| Acquired | Role | Note |
|---|---|---|
| 28 April 2023 05:19 UTC | Pre-event | Before both May floods. |
| 10 May 2023 05:19 UTC | Pre-event, recent | After a separate flood on 2–4 May (CEMS EMSR659), so not established as dry. |
| 22 May 2023 05:19 UTC | Post-event | The image the model labels. |
Model
- U-Net v1
kuro-siwo-unet-v1, run on 1,766 × 1,515 pixels in 224 × 224 chips, as it was evaluated. On the benchmark test set its flood IoU is 0.636, over 10 held-out events.- Baseline
kuro-siwo-vv-change-v1: flood where VV after the event is at most −13.5 dB and fell by at least 1.75 dB. Benchmark flood IoU 0.542.
Reference
Shown as outlines, never as labels.
- Product
- Copernicus Emergency Management Service EMSR664, AOI03,
EMSR664_AOI03_GRA_PRODUCT_v1. - Observed
- Pleiades-1A-1B optical imagery at 0.5 m, 22 May 2023 10:26 UTC: about 5 hours after the post-event radar.
- Kinds
- Flooded area; flood trace, which is deposits or damage rather than standing water; and the area CEMS mapped. Outside that area nothing was mapped, and inside it the background is unlabeled.
What the maps show
Descriptive shares, not accuracy.
Share of the 2.68 M pixels in each predicted class.
| Prediction | No water | Permanent water | Flood |
|---|---|---|---|
| U-Net v1 | 99.38% | 0.36% | 0.26% |
| Fixed VV change baseline | 96.91% | 2.47% | 0.62% |
Overlap with the CEMS delineation, inside the 0.90 M pixels CEMS mapped, where its flooded area covers 1.5%.
| Share | U-Net v1 | Fixed VV change baseline |
|---|---|---|
| Of the CEMS flooded area, predicted flood | 6.8% | 8.9% |
| Of the CEMS flood trace, predicted flood | 3.9% | 4.1% |
| Of the predicted flood, inside the CEMS flooded area | 18.0% | 12.4% |
| Of the mapped area, predicted flood | 0.56% | 1.07% |
Descriptive overlap only, not accuracy: a later optical observation, an unlabeled background and flood traces that are not standing water.
- Little open water was visible to the radar on 22 May. The model and the baseline both mark only a small part of the mapped flooded area. Shallow water among vegetation, wet soil and urban flooding often do not appear as dark open water, and five days after the peak much of the water may have receded.
- The model’s flood follows the river. Its flood patches lie along the Senio, inside the flood-trace outlines and beside the small flooded-area polygons.
- The baseline is noisier. It marks 2.5% of the area permanent water, scattered over ordinary fields, against 0.4% for the model.
Limitations
- Qualitative only: no Italian accuracy, precision or recall can be claimed without independent labels.
- One event and one area. The model was not trained on Italian data, and the scene differs from the benchmark in elevation model, radiometric level and season.
- The 28 April image is darker than the May images, and the 10 May image may still hold water from the earlier flood, so this is not a clean before-and-after pair. Water still present on 10 May can be labelled permanent water rather than flood.
- The CEMS reference is a later optical observation with an unlabeled background; it is context, not ground truth. ISPRA hazard zones are not used.
Data and credits
- Contains modified Copernicus Sentinel data (2023), processed with ESA SNAP.
- © European Union, Copernicus Emergency Management Service (2023), EMSR664 AOI03 GRA_PRODUCT v1. Underlying optical imagery is not republished.
- Terrain correction produced using Copernicus WorldDEM-30 © DLR e.V. 2010-2014 and © Airbus Defence and Space GmbH 2014-2018 provided under COPERNICUS by the European Union and ESA; all rights reserved.
- Basemap: © OpenStreetMap contributors, through Protomaps; Noto Sans under the SIL Open Font License.
- Map software: MapLibre GL JS and PMTiles; see the third-party licences.